Maritime Science On Life

Colav Lab

Native Offline Collision-Avoidance Research Platform

0:00 / 0:00
01

Opening view

Colav Lab

Watch the vessels approach one another.

Colav Lab: following decisions in a changing encounter

Colav Lab’s five-vessel open-sea narrative connects observations, movement assumptions, manoeuvre requests and vessel response within one geometry and a shared scenario clock.

The problem is the whole encounter

Clear water ahead does not, by itself, explain a manoeuvre. Traffic approaching from astern, a crossing target, a slowing vessel ahead and environmental effects can all matter to the same decision. Colav Lab is a local, offline research platform focused on examining these relationships. It connects vessel movement, alternatives and the reasoning behind a selection.

The animation develops this question through one encounter. Its initial vessels, reference route and environment come from synthetic inputs. Subsequent movements, comparison branches and outcomes are authored explanatory content. The sequence explains a decision process; it is not a recorded planner run.

Five vessels share one geometry

OWN represents our vessel, a cargo ship approximately 200 metres long and 32.26 metres wide. Four targets retain their identities throughout. T01 is the faster vessel approaching from astern. T02 crosses northward. T03 occupies the area ahead and slows during the sequence. T04 is a workboat initially heading east; its later turn prompts a second assessment.

Positions use a local east–north plane measured in metres. The reference route runs east before turning northeast and remains fixed during avoidance. Detailed views enlarge particular crossings while the overview preserves the wider encounter. Hull dimensions matter: centre-point separation and the space occupied by two hulls are different questions. The drawing plane is not a navigation chart.

Separate observation, assumption and time

All five vessels advance on the same scenario clock. T01’s movement astern, T03’s slowdown and T02’s crossing are observed within that shared time. A solid trail records movement already observed in the example. A dashed line ahead carries a movement assumption. Connecting these lines does not establish that the assumed future will occur.

The first alternatives start from the same state at 240 seconds. They are also examined at the same future instant, with the animation highlighting a snapshot 252 seconds after that observation. Crossing order can then be interpreted against requested heading and speed. Playback time is distinct from scenario time; pausing or changing the view does not create another physical event.

Heading and ground track tell different stories

The bow’s direction and the resulting ground track are followed separately. In this example, wind points northeast and current northwest. The current components are −0.65 m/s eastward and 0.75 m/s northward. Wave inputs include a significant height of 3.2 metres and a period of 8.5 seconds. These values describe the environmental context; they do not establish validated vessel response.

T04 makes the distinction visible. The first assumption holds its heading and through-water speed fixed: its bow faces east while drift carries its ground track northeast. Its subsequent northward turn must be read separately from that earlier drift. The illustration uses simplified response and drift treatment to keep movement continuous, rather than reproducing the native dynamics model.
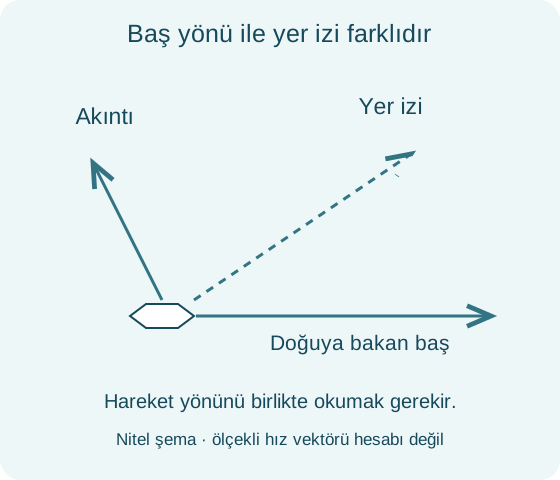
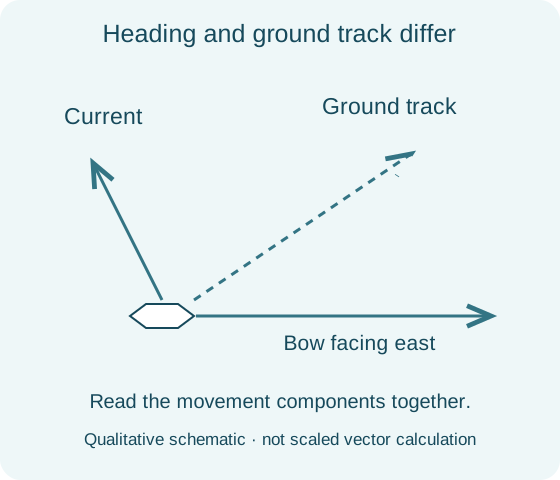
Şekil 1. Doğuya bakan baş, akıntı altında kuzeydoğuya ilerleyen yer iziyle aynı yönü göstermeyebilir. Nitel şema, ölçekli hız vektörü hesabı değildir.Figure 1. An east-facing bow can accompany a northeast ground track under current. This qualitative schematic is not a scaled velocity-vector calculation.
Figure 1. An east-facing bow can accompany a northeast ground track under current. This qualitative schematic is not a scaled velocity-vector calculation.

Compare a bounded set of requests

Three candidates enter the first comparison. A continues with a request for 0° and 6.3 m/s. B requests a port turn at +35° and 5.4 m/s. C requests a starboard turn and slowdown at −20° and 4.2 m/s. Angles follow the drawing’s local convention, with east at 0°. The candidates and comparison instant are explicit; the sequence does not claim to search every possible manoeuvre.

In A’s conditional snapshot, the drawings of OWN and T02 overlap. B moves into the northern area used by T01 and farther from the reference route. C’s lower speed gives T02 time to cross first. The narrative selects C while also examining the other three targets and route departure at that same future instant.

Response takes time, and new observations change the request

A requested state and a reached state are different. When OWN receives −20° and 4.2 m/s, heading and speed do not immediately jump to those values. Turning and slowing develop gradually while all four targets keep moving. The interval after selection therefore brings new information about both vessel response and the encounter.

T04’s observed northward turn departs from the earlier eastward assumption. At 390 seconds, a new observation anchors another comparison: retain the previous request, or slow further with 0° and 1.4 m/s. Both are examined 179 seconds ahead. Assuming T04 continues its turn, the previous request produces overlapping hull drawings; the lower-speed branch leaves time for T04 to pass ahead. Reassessment preserves the first decision’s context while responding to changed information.

Read the outcome as one segment of a voyage

Along the selected track, the first slowdown makes time for T02 and the revised request makes time for T04. Once the crossings open, OWN increases speed and progresses toward the same reference route. The state shown at 1300 seconds closes the examined segment. The route continues ahead; the sequence does not claim arrival or assessment of the entire voyage.

Review then returns to the earlier decision. The conditional forecast and later observed track can be examined together, preserving the observation times at 240 and 390 seconds. Tactical, radar-style and inclined views show the same state differently. A change of view adds no new observation source. Inputs, decisions and outcome remain linked so their sequence can be inspected.
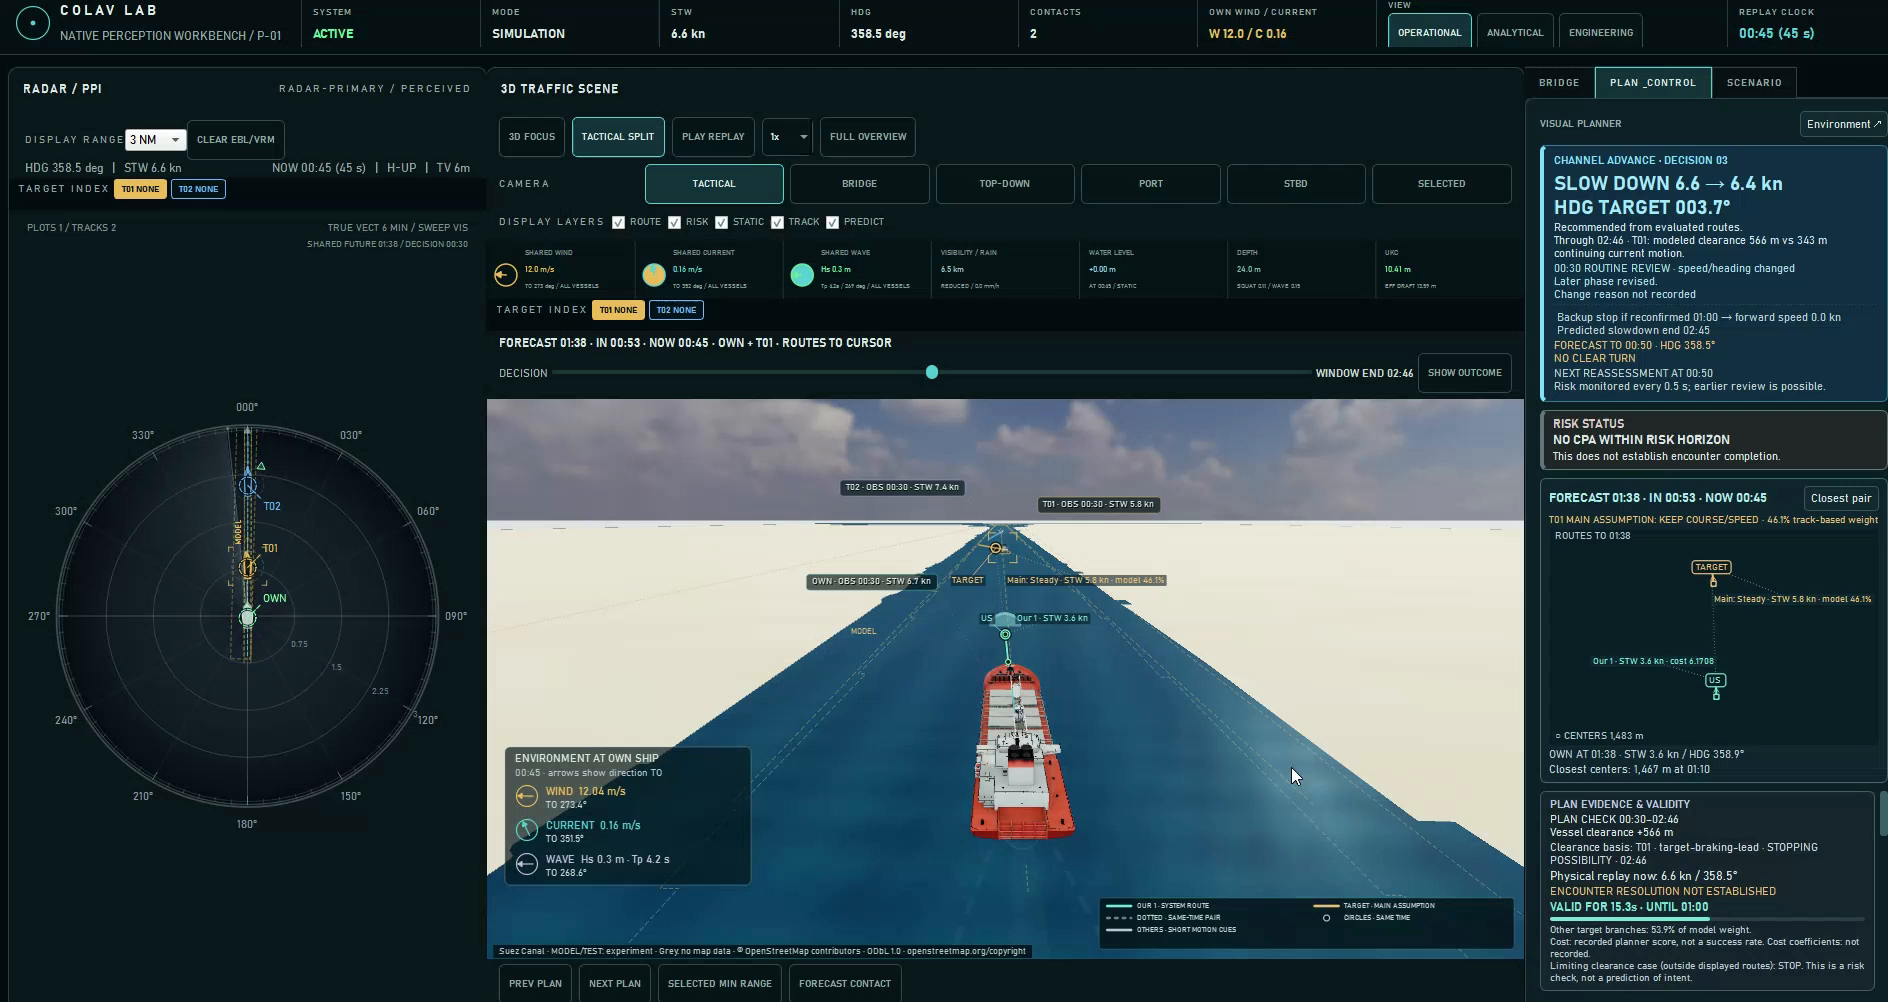
Colav Lab arayüzünde radar/PPI, üç boyutlu kanal trafiği, iki hedef ve plan inceleme panelleri.Colav Lab interface showing radar/PPI, 3D canal traffic, two targets and plan-review panels.
A native Colav Lab interface view with the scenario clock at 00:45: radar/PPI, 3D traffic and plan-review panels share one screen. This English-language Suez Canal model/test view is a different example from the five-vessel open-sea narrative above; its values do not transfer between examples.

Select the image to open it at full size.

Keep the rejected contact branch separate

A separate review reopens the rejected Continue branch. Its possible contact did not occur on the selected path. The purpose is to examine questions that arise under a different request from the same initial observation: which hull area is involved, and from which direction the approach occurs.

Approach toward a surface and sliding along it are considered separately. Damage and flooding research additionally needs verified structural and compartment inputs. Those results have not been calculated for this example, so missing information cannot be treated as zero damage. Nor does the review establish which option causes the least harm. Closing the conditional branch leaves the selected track’s state at 1300 seconds unchanged.
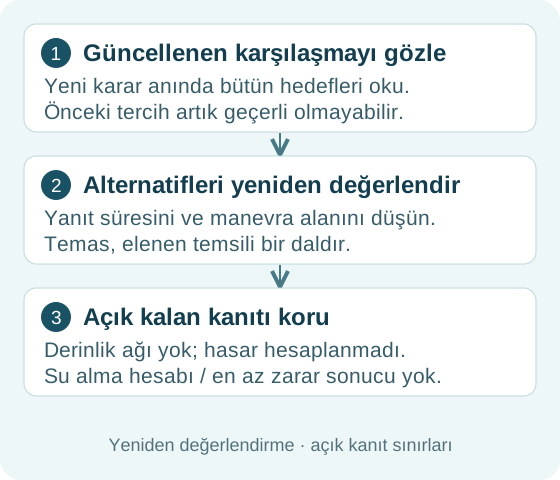
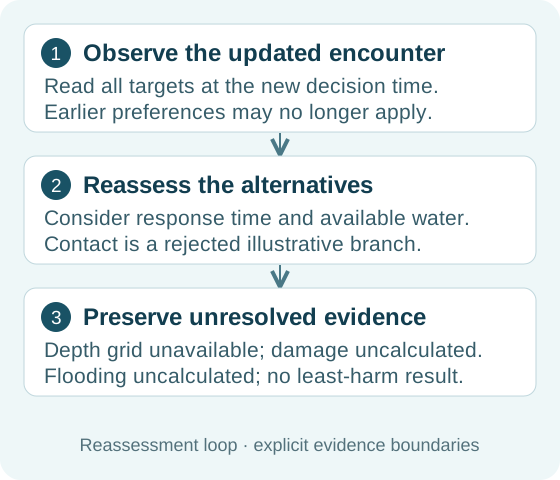
Şekil 2. Yeni gözlem, yeni değerlendirme gerektirebilir. Temas dalı seçilmiş yolun gerçekleşmiş olayı değildir; eksik hasar verisi sıfır hasar anlamına gelmez.Figure 2. New observations can require reassessment. The contact branch is not an event on the selected path; missing damage data does not mean zero damage.
Figure 2. New observations can require reassessment. The contact branch is not an event on the selected path; missing damage data does not mean zero damage.

An inspectable record and a clear research boundary

This explanation connects observation, selection, request, response and reassessment, showing which information remains fixed and which changes. Further research would need recorded solver output tied to the same inputs, times and alternatives, alongside examination of model assumptions and the limits of the results. That validation is not presented as completed here.

This example has no native solver replay, depth grid or calculated under-keel clearance. Its movement and outcome remain illustrative. The page therefore provides no operational navigation recommendation, compliance certification or validated safety result. It offers an explicit framework for examining the questions, assumptions and decision points within a multi-vessel encounter.

Original Work Record
Work
Colav Lab: following decisions in a changing encounter
Author
yönetici
Recorded (UTC)
2026-11-15T04:13:54.775Z
Version
11
SHA-256
67c7ee5e9f4f7bae6b6d568439c5227c38cb8f70fb7a0673225eb9536a492c00

Credit the author and source when quoting or using this work.

Image records in this work

Kullanıcıya ait proje görsel sunumu · colav-lab-lockup.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:24.671Z
Version
1
SHA-256
609045662e1b93ce262b0acfb3187290af788240b0e9502992095c4a75d02dee

Kullanıcıya ait proje görsel sunumu · colav-comparison.tr.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:12.811Z
Version
1
SHA-256
70ae08a0ec77d48794d13d6993fb7840b9085c933257972c82da5e39e3a22552

Kullanıcıya ait proje görsel sunumu · colav-comparison.en.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:12.584Z
Version
1
SHA-256
0501a4a13de517cf88446ed0994291a06ac8aa3a48875cf487eb59c2c213420b

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision.png

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:07.597Z
Version
1
SHA-256
95f86a33d3df2aa56fc71e68e259afd48a2317b721cad6e532370804e31ac04f

Kullanıcıya ait proje görsel sunumu · colav-reassessment.tr.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:14.279Z
Version
1
SHA-256
838b8c7f939080e1779a2e97c8335a86a0f55f215b1f604c8b8add3aef748fc3

Kullanıcıya ait proje görsel sunumu · colav-reassessment.en.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:13.893Z
Version
1
SHA-256
f9a69f269811c8b25e4a3afdda8aa3c3579ed6ce3a9d70f876df44a3d1eade4c

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-bridge.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:02.732Z
Version
1
SHA-256
1a913b8901924089ec318e08fc4b1608a734f78d19b56669f87ac0f90a591a04

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-planner.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:03.877Z
Version
1
SHA-256
0bdf08475d8a9660c539ec4e6eff2fc8881e5be1b8f920f9c88cf375eb2aaa94

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-route.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:03.586Z
Version
1
SHA-256
0cf06c2c4ae9921e873c74b6fe06ad7d348e86cfb0cf914675a705e916046657

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-tactical.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:01.807Z
Version
1
SHA-256
640d268db9fa91344467976f4e54dead97346222e6568e4e7aa7a10f40c067f9

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-traffic.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:01.682Z
Version
1
SHA-256
6a6cc767ec679a921304d780da456ab96c3c45a9e0e0b996abdb40110189501f

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-bridge.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:43.690Z
Version
1
SHA-256
eccc542c48d32f7a06524f2db7110ab5c1fc49d7d2b4949877179b01ac82c637

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-planner.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:45.730Z
Version
1
SHA-256
4558c8b724b3004890cc1bed8361ab5a02288b81147ecdb222d8c4afbec631e9

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-route.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:44.724Z
Version
1
SHA-256
d432cd1a9238e6817d9458ec3cd75df4fca971bfc7f629e84e47adaf062df283

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-tactical.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:42.955Z
Version
1
SHA-256
0cadee5b10ef3cfbf455149c4ca4fef85777e5ef212d8d952dadf1a23cead276

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision-traffic.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:42.291Z
Version
1
SHA-256
1262d9d60f585c9aecd29a847c9fd3db5c0fce302dac6c5210b64131cb57788d

Kullanıcıya ait proje görsel sunumu · colav-symbol.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:18.859Z
Version
1
SHA-256
4c919f6039fb71284df75a60be1a5e1aa98ab1d58cc38d60cdeac2f8acca7879

Kullanıcıya ait proje görsel sunumu · colav-clearance.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:21.107Z
Version
1
SHA-256
c616eda0cabd60f4303fd5faca4bc5f376970649b06f7664075e9ca7d295f3a1

Kullanıcıya ait proje görsel sunumu · colav-clearance.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:22.164Z
Version
1
SHA-256
9b0704cdd9e22c00665773e57962959643f088cd091c3d5672eced80cf027e51

Kullanıcıya ait proje görsel sunumu · colav-clearance.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:23.877Z
Version
1
SHA-256
aca5db420be0e7bc0a01e6d5b0bbc051eef592120b07d5621e72d1818fd8ebdf

Kullanıcıya ait proje görsel sunumu · colav-lab-symbol.svg

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:25.348Z
Version
1
SHA-256
abfda786c071e427f75f6528e232fdb41ab70325691123985558d25ead231eb9

Özgün proje sunumu ve doğrulanmış ekran kaydı · collision.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:46:08.431Z
Version
1
SHA-256
2a21ef9239b66f77822124eb22b32fbc45fb1368b2e53f292122bc0aa0134ac1

Bağımsız oluşturulmuş özgün görsel · colav-camera-00.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:17.223Z
Version
1
SHA-256
e0e85330c776e7fa55940c55d4bfe952a1d8adfb6854b3955974f0cb7053197d

Bağımsız oluşturulmuş özgün görsel · colav-camera-01.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:19.026Z
Version
1
SHA-256
251efbe806911979131b80c3e6ff4486afdd1cb0af969e28d1191b8a7147391e

Bağımsız oluşturulmuş özgün görsel · colav-camera-02.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:18.863Z
Version
1
SHA-256
06bcd8f4caba6ef3c9c3c307ec9cabea4b6b75a4a0057fc988a1510d1d09c6db

Bağımsız oluşturulmuş özgün görsel · colav-camera-03.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:21.186Z
Version
1
SHA-256
11ab2059665c231ff592a2325937a534c7256f9750aaff83d4eb919a4d94ec0a

Bağımsız oluşturulmuş özgün görsel · colav-camera-04.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:20.863Z
Version
1
SHA-256
7d0dced6ff6f58288f60b9ed4ac932904e4278e974faac73f66815e85633c912

Bağımsız oluşturulmuş özgün görsel · colav-camera-05.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:22.777Z
Version
1
SHA-256
928caf16355262ace96f650986e6161c6157b2072dc757a111f766aa77722aec

Bağımsız oluşturulmuş özgün görsel · colav-camera-06.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:22.655Z
Version
1
SHA-256
1efc7e3b8aa8be4244e790710a4981c1fc982e1095114d821446fb060ac12bac

Bağımsız oluşturulmuş özgün görsel · colav-camera-07.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:24.056Z
Version
1
SHA-256
511da22e53618926d2d8fc7504069df8e5b765fa758d22b45911cee9ec6308d6

Bağımsız oluşturulmuş özgün görsel · colav-camera-08.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:24.236Z
Version
1
SHA-256
81e4a604870f5f3f1fc3de2346ef062af46596e5d519e6dd05c659e34c604b9c

Bağımsız oluşturulmuş özgün görsel · colav-camera-09.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:25.683Z
Version
1
SHA-256
3e01f0dd305b9d96a41eb1ab51b8b177840e7996ae06daec1b236a1c2f86a19c

Bağımsız oluşturulmuş özgün görsel · colav-camera-10.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:25.346Z
Version
1
SHA-256
6a2832bb911556cd0144094c96b70813ab196b16c81b32fdffea98e1b9ed43f7

Bağımsız oluşturulmuş özgün görsel · colav-camera-11.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:27.358Z
Version
1
SHA-256
6cc95e87648ee45d9112602f9432ef004f347e8e9b2ea005eed1f8258b0b903e

Bağımsız oluşturulmuş özgün görsel · colav-camera-12.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:27.182Z
Version
1
SHA-256
3965cb2cd5f63734c8e36dd3da610e3e4b3ea41bbe897945a212345e35a6876c

Bağımsız oluşturulmuş özgün görsel · colav-camera-13.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:29.279Z
Version
1
SHA-256
a459b3c409fe49f100ab9ea0a7337ba71cbfd3e22a88e15299ed8ab0de03de67

Bağımsız oluşturulmuş özgün görsel · colav-camera-14.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:29.968Z
Version
1
SHA-256
f7274805e0286b5b1f4d104d13c2e08111974dae9e47dab3f356ff869d4748de

Bağımsız oluşturulmuş özgün görsel · colav-camera-15.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:30.594Z
Version
1
SHA-256
69eb0e9bbd318fae02543be3bb98a5c3bbaab4fb974152a923d61b747c9016e3

Bağımsız oluşturulmuş özgün görsel · colav-camera-16.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:31.312Z
Version
1
SHA-256
71ab01d5766532276e3db8173ecc427427bc950f13f6b2e1b4c544c03e80b039

Bağımsız oluşturulmuş özgün görsel · colav-camera-17.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:31.367Z
Version
1
SHA-256
67c65b5f8fad9a9343e1691652bc825922799ba4e61043432de2fbb7b0283604

Bağımsız oluşturulmuş özgün görsel · colav-camera-18.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:32.467Z
Version
1
SHA-256
702f43814186e637055f728679e0870ac6c3931cd89eadaa56d3ff9a8c7a3f87

Bağımsız oluşturulmuş özgün görsel · colav-camera-19.webp

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:32.748Z
Version
1
SHA-256
a9bca8d25b651fea3b1c6e6024aa57a10b063e8af11c8bfa188173adfaba144e

Bağımsız oluşturulmuş özgün görsel · cargo-cutout-heading-a.png

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:33.473Z
Version
1
SHA-256
451abc9321b0341c56d2d4fd59343c062b21535f77d0237eb957fc0be53aa2b4

Bağımsız oluşturulmuş özgün görsel · cargo-cutout-heading-b.png

Author
yönetici
Recorded (UTC)
2026-10-18T22:45:34.044Z
Version
1
SHA-256
baebecbd9bb2486a73154f37c967fa147f6ec2feabe5ee77ef50a8955ae9da01

Edited native-view sequence · illustrative data